
Robot Arm Take-Out and Handling Demo
A KEFAN robot arm demonstration showing repeatable take-out and handling for molded products and downstream transfer.
Challenge
Demonstrate a repeatable molded-part take-out path and a controlled handoff to the downstream process.
Solution
- Molded-part take-out
- Repeatable handling path
- Product transfer
- Application-specific end-of-arm tooling
Result
The demonstration makes the take-out and transfer sequence visible for application review, helping confirm the required robot motion, tooling and release position before quotation. Production cycle and capacity are validated against the customer’s machine, mold and part.
Project Scope
- Molded-part take-out
- Repeatable handling path
- Product transfer
- Automation demonstration
What to Confirm for a Similar Project
- Injection molding machine model, clamping force and mold layout
- Part and runner dimensions, weight and release direction
- Required payload, reach, placement position and downstream process
- EOAT functions, machine signals, cycle window and guarding
Share the available details with KEFAN engineering for an application review.
Watch the Project Video
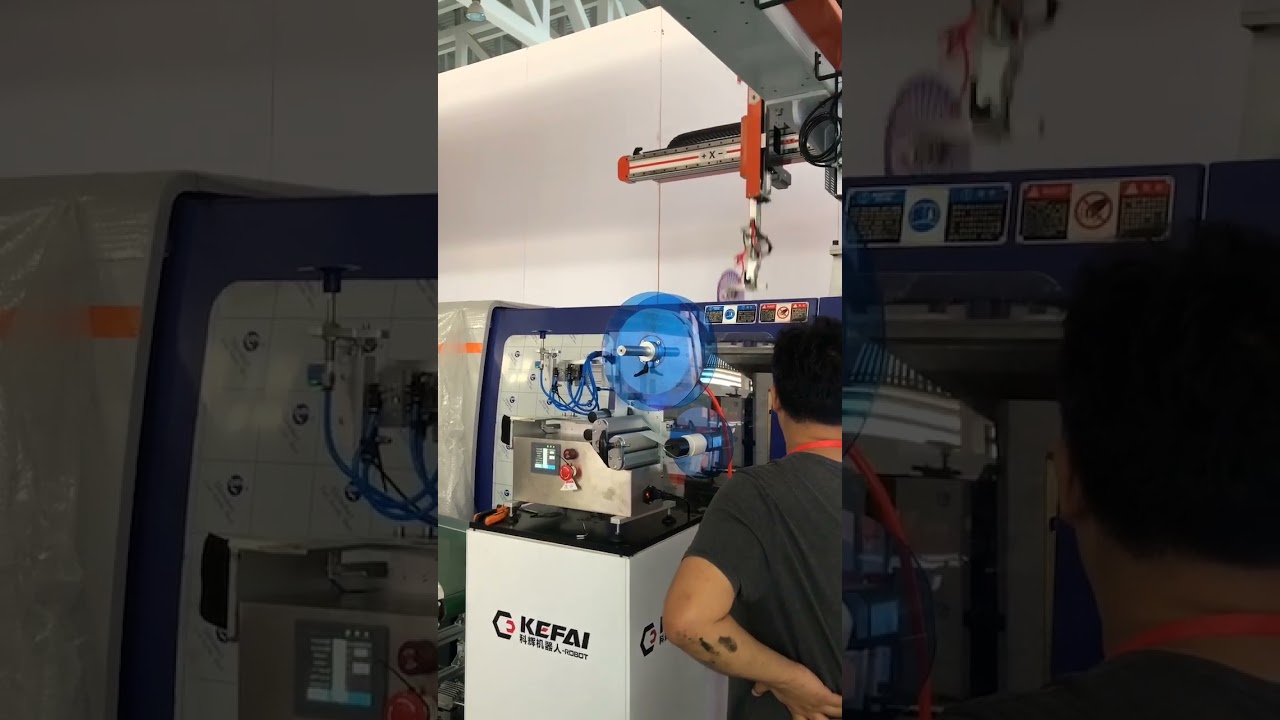
For a similar application, review our injection molding robots or send your machine, mold, part and target cycle to our engineering team.
Project facts that are publicly confirmed
| Field | Confirmed information |
|---|---|
| Industry | Injection molding robot demonstration for molded-part take-out and downstream handling. |
| Production line | A demonstration sequence is shown; a customer production-line count is not publicly disclosed. |
| Machine and mold | Machine model, clamping force, mold layout, part and runner dimensions, weight and release direction are required for a comparable project; demonstration values are not published. |
| EOAT | Application-specific end-of-arm tooling is in scope; the actual tooling design and payload are not publicly disclosed. |
| Interfaces | Machine signals, downstream transfer, cycle window and guarding are identified as review items. |
| Commissioning and acceptance | This page describes a demonstration, not a customer acceptance record. Cycle and capacity require validation against the customer’s machine, mold and part. |
| Customer permission | No customer identity or permission statement is published. Customer-identifying media, logos, testimonials or results require written approval. |
Disclosure boundary: The demonstration illustrates motion and handling; it is not presented as an unverified production guarantee.