
Automated Container Handling Robot
KEFAN developed this automated handling application for molded containers that need stable pickup, transfer and organized downstream output after injection molding.
Application Scope
- Automatic pickup of molded containers after mold opening
- Controlled transfer from the injection molding machine to the downstream station
- Product handling matched to the container shape, release direction and cavity layout
- Prepared output for packing, inspection or the next production step
Engineering Review
A reliable injection molding robot cell starts with the part and mold data. Our engineers review container dimensions, material, weight, cavity layout, release temperature, acceptable contact areas and deformation risk before selecting the robot stroke, payload and end-of-arm tooling.
Robot and EOAT Integration
The robot configuration is matched to the injection molding machine size, mold-open window and available floor space. EOAT can be arranged for the required pickup pattern and orientation, while vacuum or pneumatic functions can be reviewed when the product surface and process require them. Machine signals, guarding and downstream equipment are confirmed during integration planning.
What This Cell Helps Control
- Repeatable part pickup and transfer
- Consistent placement orientation
- Clear separation between molded parts and the next handling step
- A defined interface for conveyor, counting, inspection or packing equipment
Information Needed for a Quotation
Send the injection molding machine brand, model and clamping force, plus part dimensions, material, weight, mold cavity layout, target cycle, required orientation, downstream process and available layout. These details allow KEFAN to recommend a suitable injection molding robot, EOAT and control interface.
Watch the Project Video
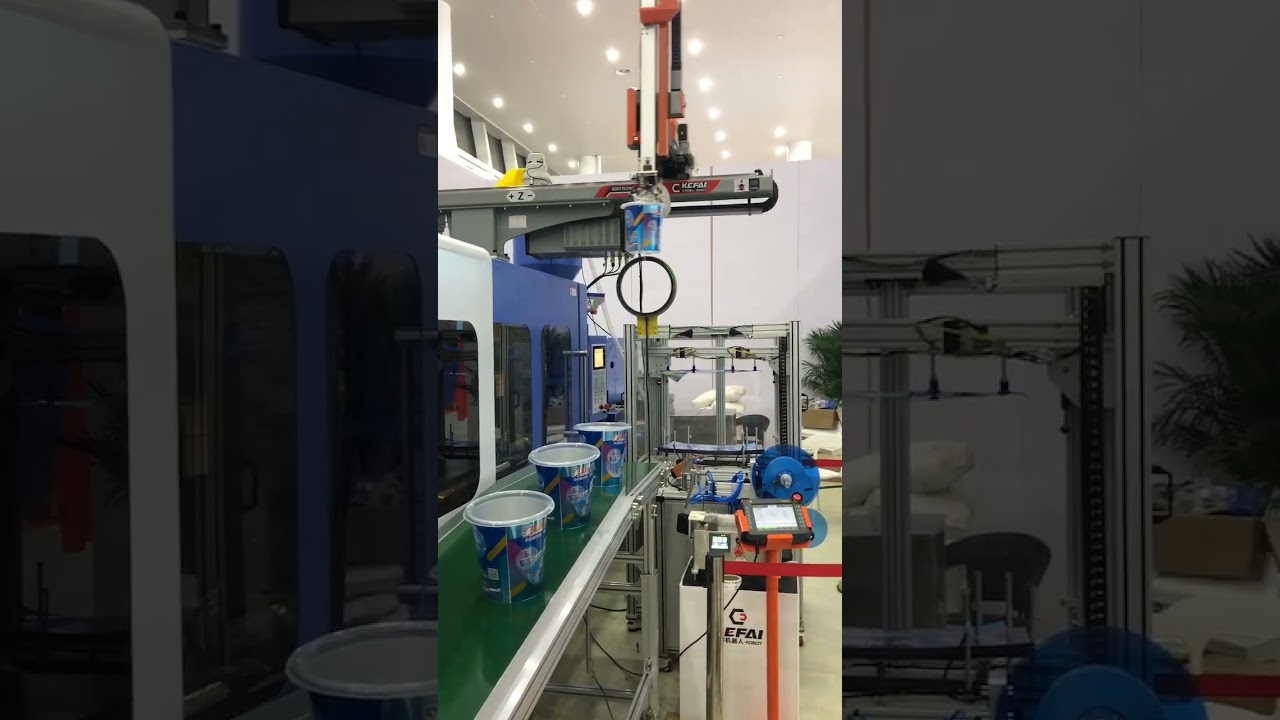
For packaging-related projects, review our packaging injection molding automation page. To discuss a similar cell, send your machine, mold and part details to the KEFAN engineering team.
Project facts that are publicly confirmed
| Field | Confirmed information |
|---|---|
| Industry | Injection molding automation for molded container handling. |
| Production line | Automated pickup, transfer and downstream output for packing, inspection or the next production step; exact line count is not publicly disclosed. |
| Machine and mold | Container dimensions, material, weight, cavity layout, release temperature and deformation risk are identified as engineering inputs; project values are not published. |
| EOAT | EOAT is matched to container shape, pickup pattern and orientation; actual tooling layout and payload are not publicly disclosed. |
| Interfaces | Machine signals, guarding, vacuum or pneumatic functions and conveyor, counting, inspection or packing equipment are part of the review. |
| Commissioning and acceptance | Process and integration review are described; project-specific acceptance criteria and signed results are not publicly disclosed. |
| Customer permission | No customer identity or permission statement is published. Customer-identifying media, logos, testimonials or results require written approval. |
Disclosure boundary: The application scope is public; unreported machine, mold, cycle-time and ROI data is intentionally left unclaimed.