
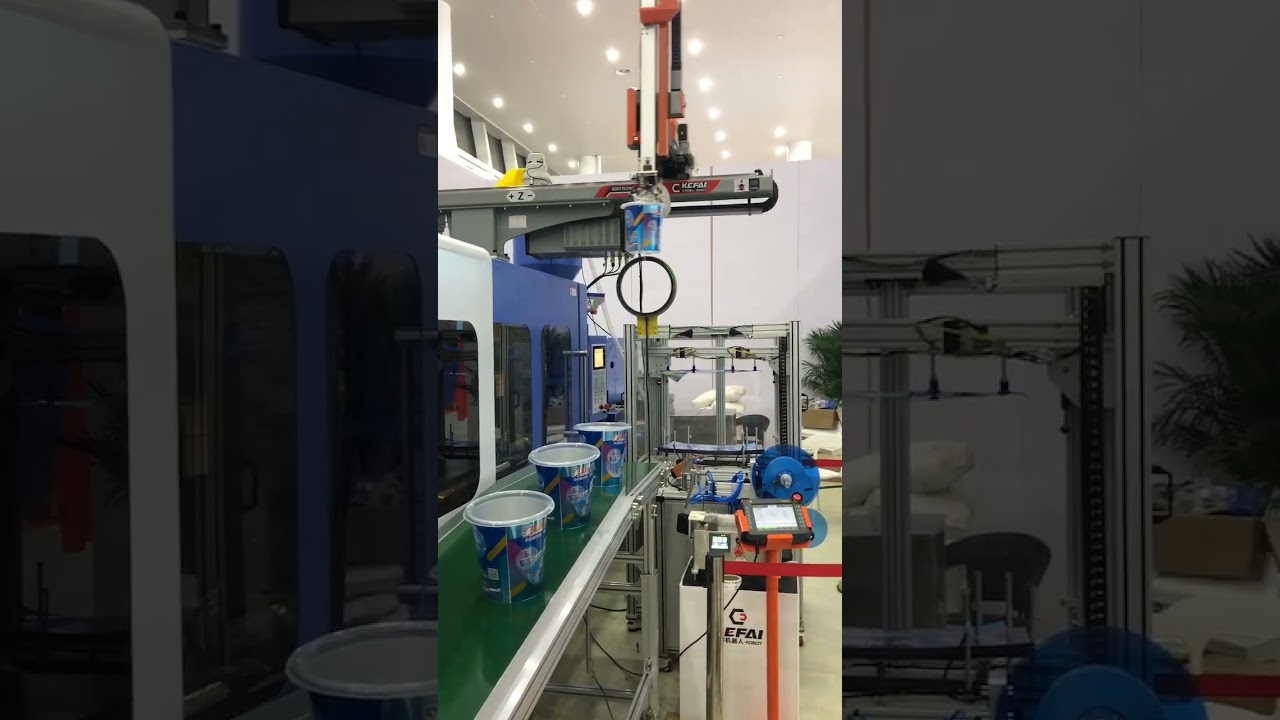
Automated Pick-and-Place Robot Cell
A practical pick-and-place automation cell coordinating robot motion, tooling and downstream positioning around the production sequence.
Challenge
Coordinate robot take-out, tooling and downstream positioning in one repeatable production sequence.
Solution
- Robot pick-and-place motion
- Application-specific end-of-arm tooling
- Defined placement position
- Coordinated cell sequence
Result
The cell provides a defined placement path and coordinated handling sequence for consistent production transfer. Final cycle time and capacity are confirmed against the customer’s machine, mold and part during application review.
Project Scope
- Robot pick-and-place motion
- Application-specific tooling
- Defined placement position
- Coordinated cell sequence
What to Confirm for a Similar Project
- Injection molding machine, mold layout and part dimensions
- Pickup points, EOAT contact surfaces and required orientation
- Placement positions, downstream fixtures and transfer sequence
- Target cycle, machine signals, guarding and available floor space
Share the available details with KEFAN engineering for an application review.
Watch the Project Video
For a similar application, review our automation solutions or send your part, machine and target cycle to our engineering team.