
Resources
Automated Injection Molding: A Practical Planning Guide
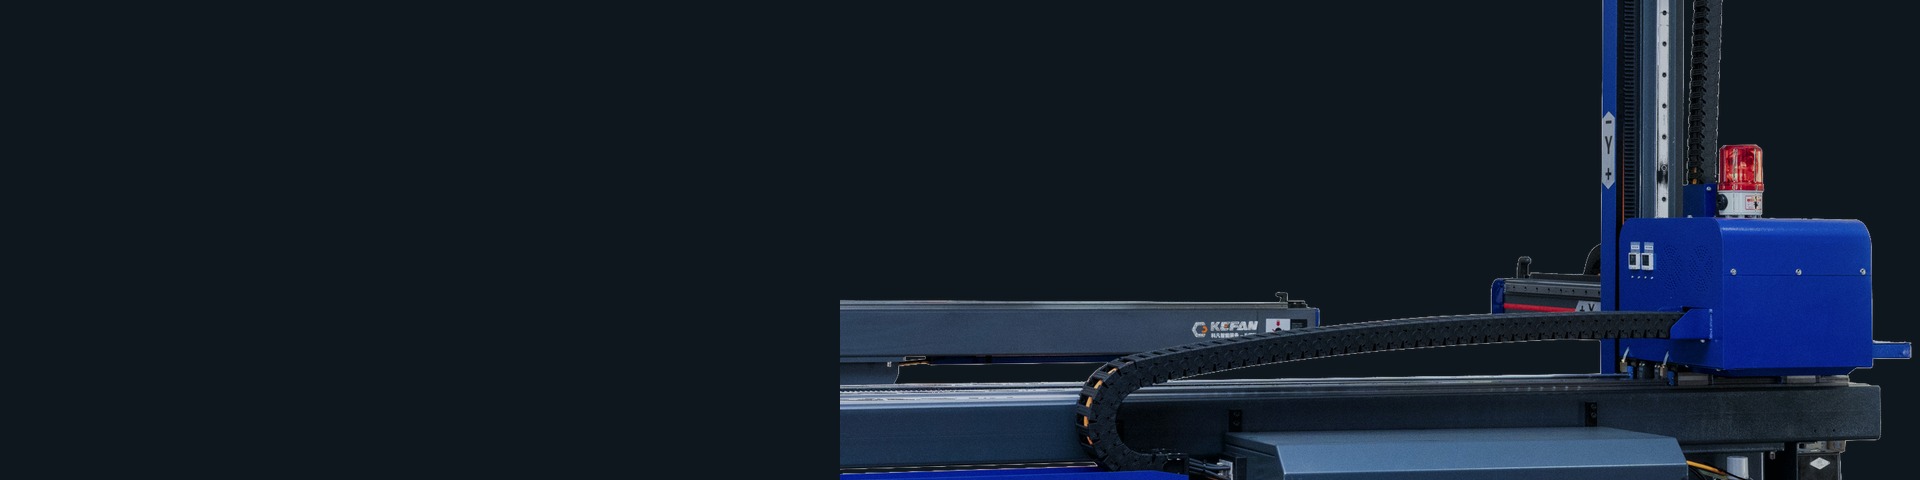
Automated injection molding connects the molding machine, robot, end-of-arm tooling (EOAT), and downstream handling into one coordinated production process. A successful project starts with the molded part and required task, not with the robot model alone.
This guide explains how to plan an automated injection molding cell, which technical inputs affect robot selection, and when simple part removal should expand into a broader automation system.
What Is Automated Injection Molding?
Automated injection molding uses handling equipment to perform one or more repeatable tasks around an injection molding machine. The most common starting point is removing a molded part or runner from the open mold. Depending on the application, the process can also include insert loading, sprue separation, sorting, stacking, inspection, assembly, transfer, or packaging.
The automation scope should match the real production requirement. Some cells need only a reliable top-entry robot and a simple gripper. Others require custom EOAT, conveyors, fixtures, sensors, guarding, and communication with downstream equipment.
Which Parts of the Injection Molding Process Can Be Automated?
Part and runner removal
A robot can enter the mold area after the machine reaches the correct mold-open position, grip the part or runner, confirm the grip, and remove it before the next molding cycle. The motion path and timing must be reviewed together with the mold and machine sequence.
Insert loading
For insert molding, automation may present or load inserts before the mold closes. Insert orientation, feeding consistency, fixture design, and confirmation sensors become important parts of the cell.
Sorting, stacking, and placement
After take-out, the robot may place parts on a conveyor, separate acceptable parts from runners, stack products in a defined orientation, or transfer them to another station. These tasks affect the required axes, stroke, payload, EOAT, and working envelope.
Downstream handling
Some projects continue into inspection, degating, assembly, labeling, packaging, or palletizing. These operations may require custom automation around the primary injection molding robot.
How to Plan Automated Injection Molding in 5 Steps
- Define the part and mold conditions. Record the part dimensions, material, weight, mold layout, cavities, runner arrangement, release direction, and any surface areas that must not be marked.
- Map the required robot task. Specify whether the robot will remove parts, separate runners, load inserts, sort, stack, transfer, or serve another downstream process.
- Review the injection molding machine. Confirm the machine brand, model, clamping force, tie-bar spacing, available robot interface, mold-open position, and installation space.
- Select the robot and EOAT together. Evaluate payload, stroke, reach, entry direction, axes, EOAT weight, grip method, and placement position as one application.
- Validate the complete cell sequence. Review machine signals, robot motion, grip confirmation, guarding, downstream equipment, recovery conditions, and the target cycle before finalizing the configuration.
Robot Selection Factors for an Automated Molding Cell
Machine size is only the starting point
Injection molding machine tonnage helps narrow the selection, but it does not determine the robot by itself. Tie-bar spacing, mold dimensions, vertical and traverse strokes, part removal direction, payload, and available ceiling or floor space can change the required configuration. See our guide on selecting an injection molding robot by machine tonnage.
Payload must include the EOAT
The robot carries more than the molded part. Selection should consider the combined load of the part, runner, EOAT, fittings, and any additional components that move with the wrist. The grip position and load distribution also matter.
Three-axis or five-axis motion
A three-axis servo robot may be suitable when the process requires direct take-out and simple placement. A five-axis configuration can support additional orientation or more complex placement tasks. The required movement after the part leaves the mold should guide the decision. Compare the options in our 3-axis vs. 5-axis injection molding robot guide.
Top-entry or side-entry layout
Top-entry robots are widely used for part removal and handling across different machine sizes. Side-entry robots may be considered when fast lateral access, a specific mold layout, or limited overhead space makes the arrangement appropriate. The final layout should be checked against the complete machine and cell envelope.
Why EOAT Is Critical
EOAT is the connection between the robot and the molded product. Its design determines how the part is gripped, supported, detected, protected, and released. Vacuum cups, grippers, sensors, frames, and quick-change components should be selected around the actual geometry and process.
A robot with sufficient reach can still perform poorly if the EOAT interferes with the mold, marks the part, allows movement during transfer, or lacks reliable grip confirmation. Read how to design EOAT for an injection molding robot for a more detailed engineering checklist.
Machine Interface and Safety Considerations
The robot and injection molding machine must exchange the correct signals before either device moves. Interface requirements should be confirmed for the actual machine and controller configuration. Guarding, access doors, emergency stops, safe recovery, maintenance access, and operator procedures should also be reviewed as part of the complete cell.
Interface availability does not replace application validation. The machine, robot, EOAT, and downstream equipment must be tested as one coordinated sequence before production use.
When Does a Simple Take-Out Robot Become Custom Automation?
A standard take-out arrangement may be enough when the job ends with removing a part and placing it in a consistent location. A broader automation project may be appropriate when the process also requires insert feeding, controlled orientation, inspection, assembly, multiple placements, stacking patterns, packaging, or communication with several devices.
KEFAN supports injection molding robots, application-specific EOAT, and injection molding automation solutions. The final scope is defined after reviewing the part, mold, machine, available space, and downstream process.
Information to Prepare for Robot Selection
- Injection molding machine brand, model, and clamping force
- Part drawing, dimensions, material, and weight
- Mold dimensions, cavities, runner, and release direction
- Required robot task and placement position
- Available mold-open time or target production cycle
- EOAT, insert loading, inspection, conveyor, or downstream requirements
- Available installation space, guarding, and interface information
You do not need every detail before starting a discussion. Available drawings, photos, machine information, or a production video can help identify the next technical questions.
Frequently Asked Questions About Automated Injection Molding
What is automated injection molding?
Automated injection molding uses robots and related handling equipment to perform repeatable tasks around an injection molding machine, such as part removal, insert loading, sorting, stacking, transfer, inspection, or downstream handling.
Which robot is used for injection molding automation?
Many applications use linear top-entry or side-entry robots. The appropriate configuration depends on the machine, mold, part, payload, working envelope, required motion, placement position, and downstream task.
Can an injection molding robot work with an existing machine?
It may be possible, but compatibility must be checked. The review should cover the machine interface, mounting arrangement, tie-bar spacing, mold-open position, available space, robot strokes, safety system, and production sequence.
How do I choose EOAT for an injection molding robot?
Start with the part geometry, material, temperature, surface requirements, grip points, release direction, runner arrangement, and combined tooling load. The design should also include reliable grip confirmation and adequate mold clearance.
Does automated injection molding always require a custom system?
No. Some applications only require a standard robot and application-specific EOAT for part removal. Custom automation is more relevant when the process includes multiple downstream operations, special fixtures, inspection, assembly, or complex product handling.
What information does KEFAN need to recommend a robot?
Useful inputs include the machine model and clamping force, part and mold information, product weight, required task, placement position, available space, target cycle, EOAT needs, and downstream process. KEFAN can identify missing information during the application review.
Discuss Your Automated Injection Molding Application
If you are planning a new cell or adding automation to an existing injection molding machine, send the information currently available. KEFAN can review the machine, mold, part, robot task, EOAT, working envelope, and downstream requirements before recommending a configuration.
Discuss Your Application or send your machine and part details for an initial robot selection review.
Injection Molding Robot in Action
KEFAN injection molding robot automatically taking a molded part from the machine with fast, repeatable handling.